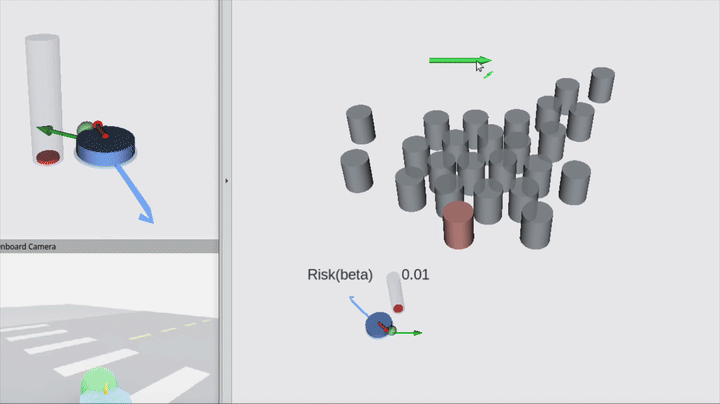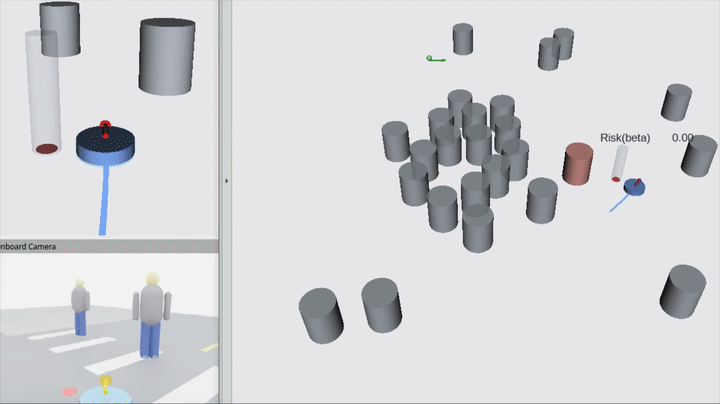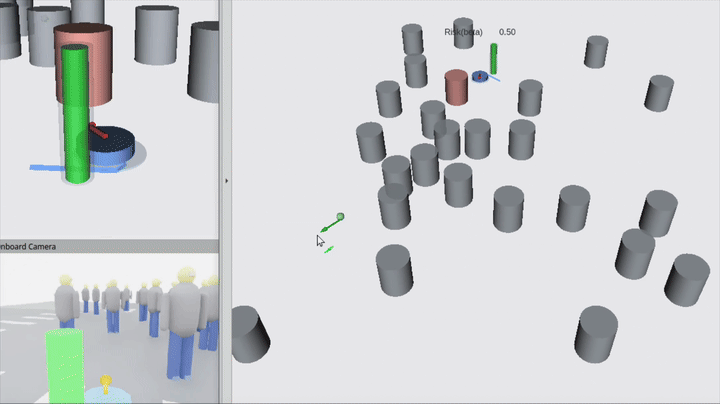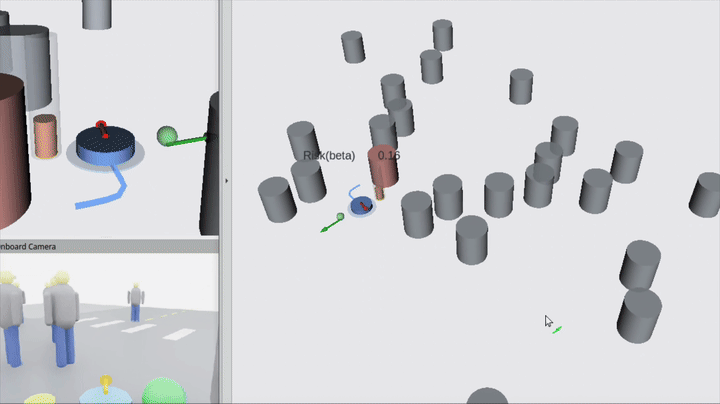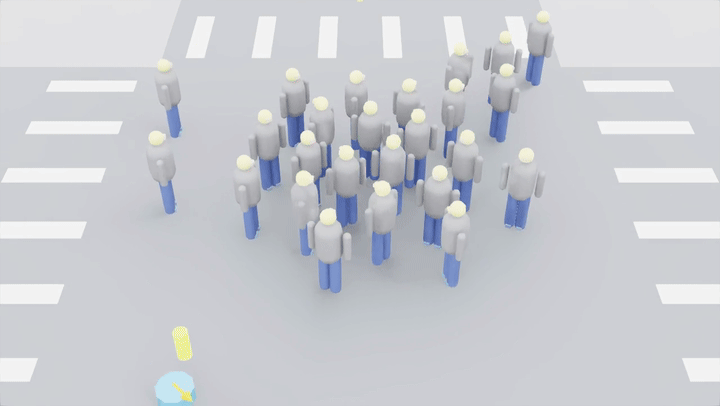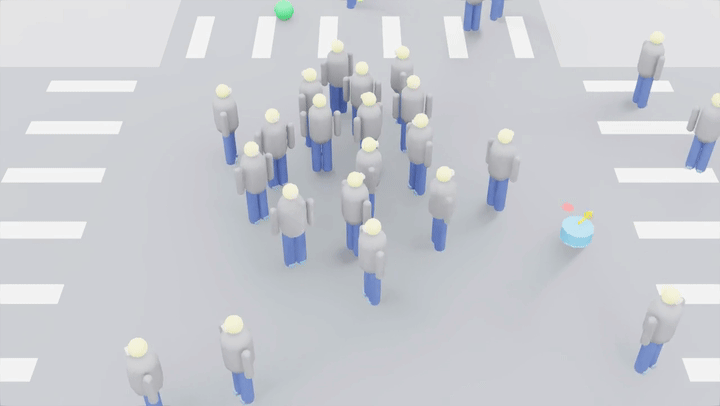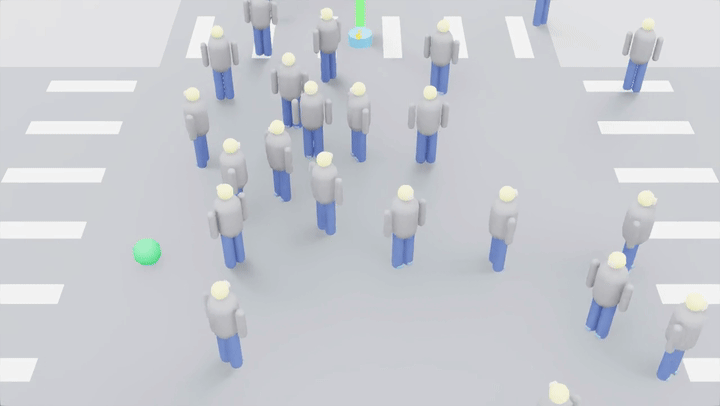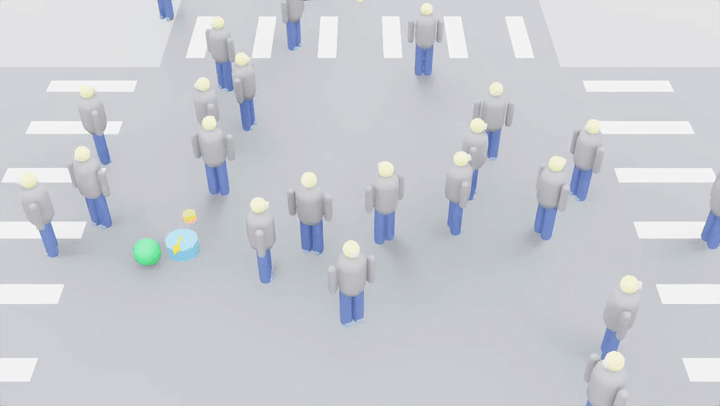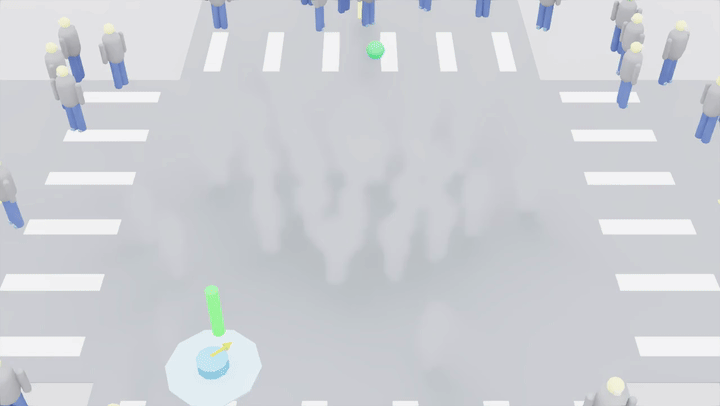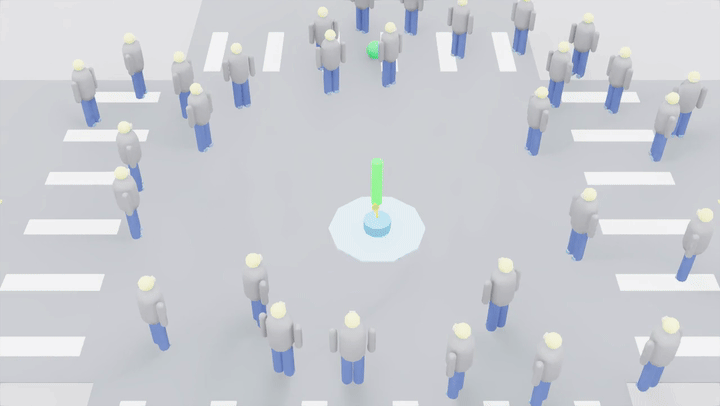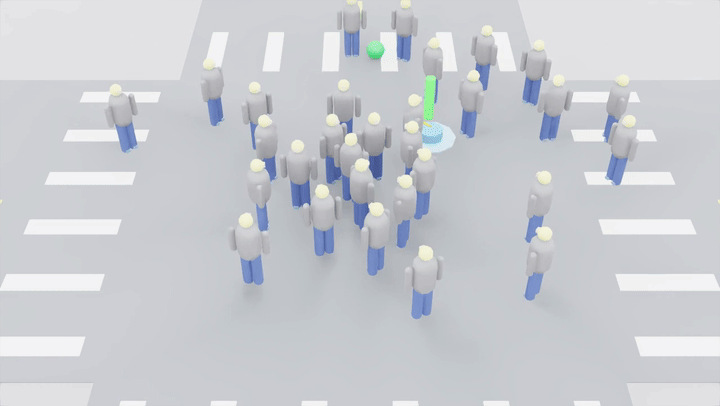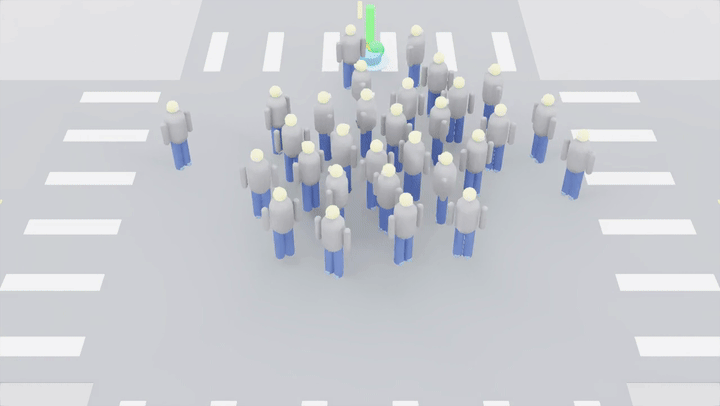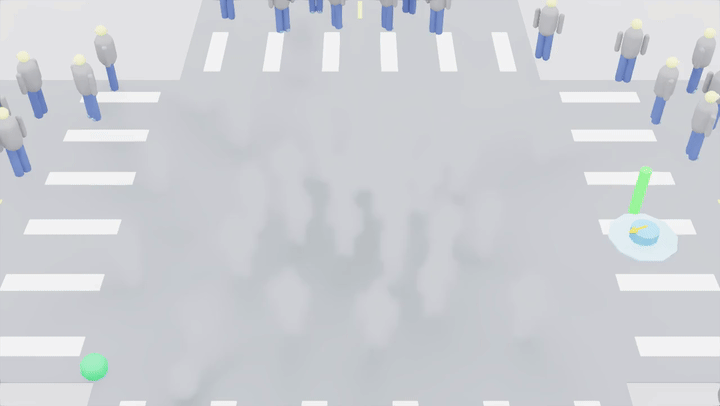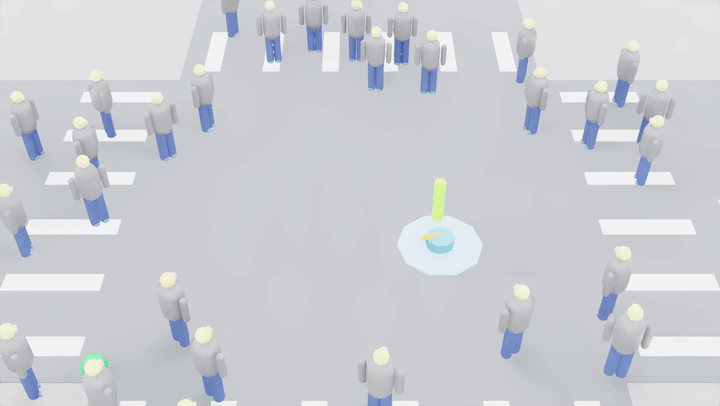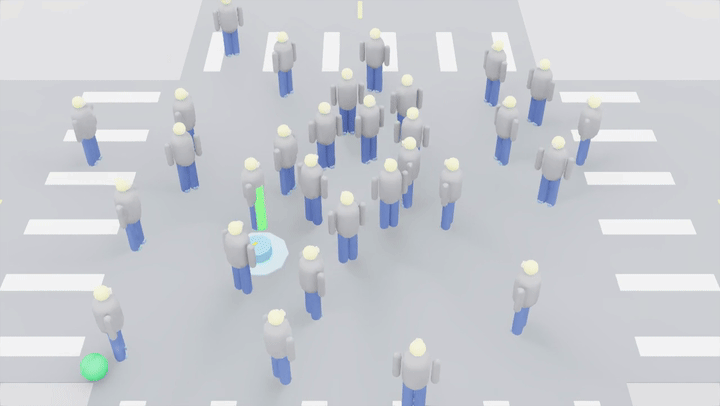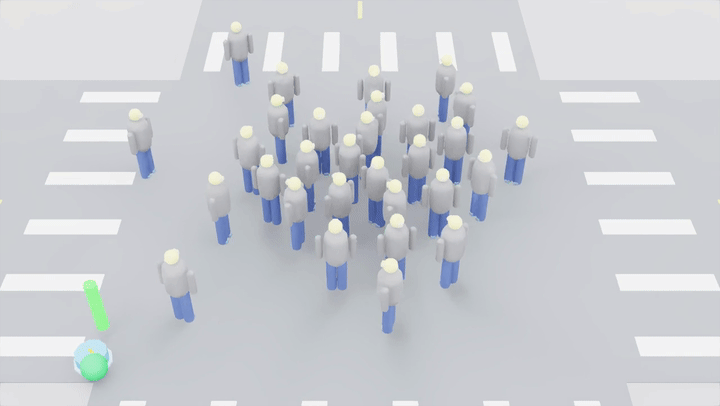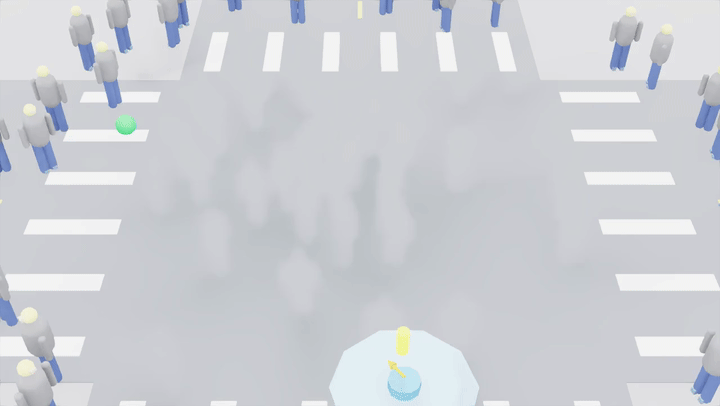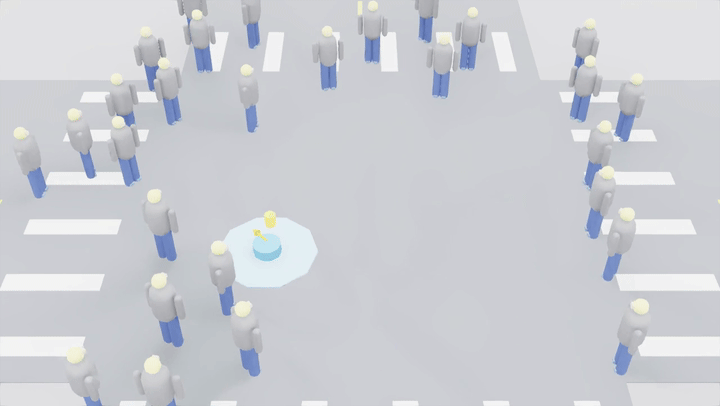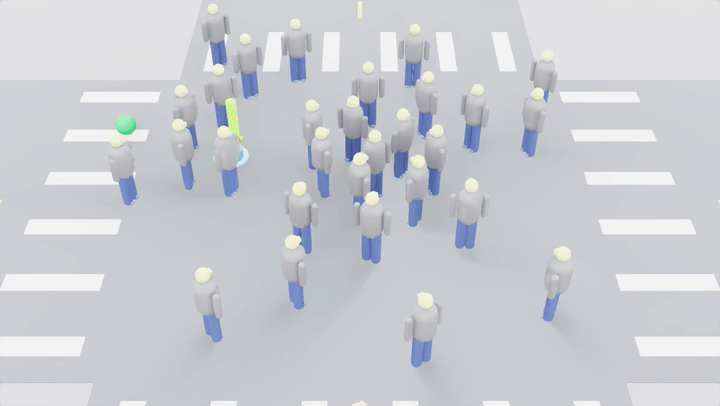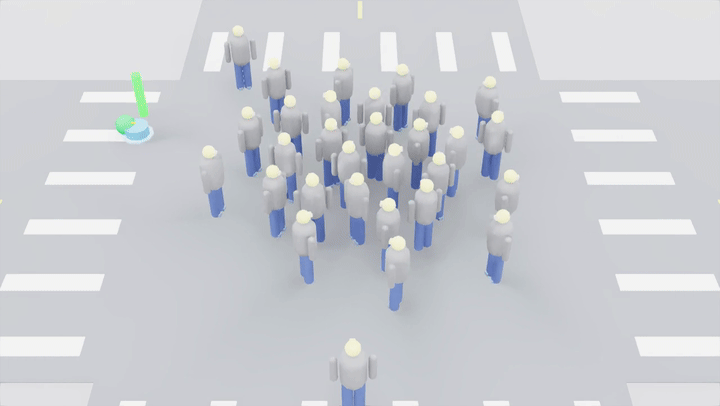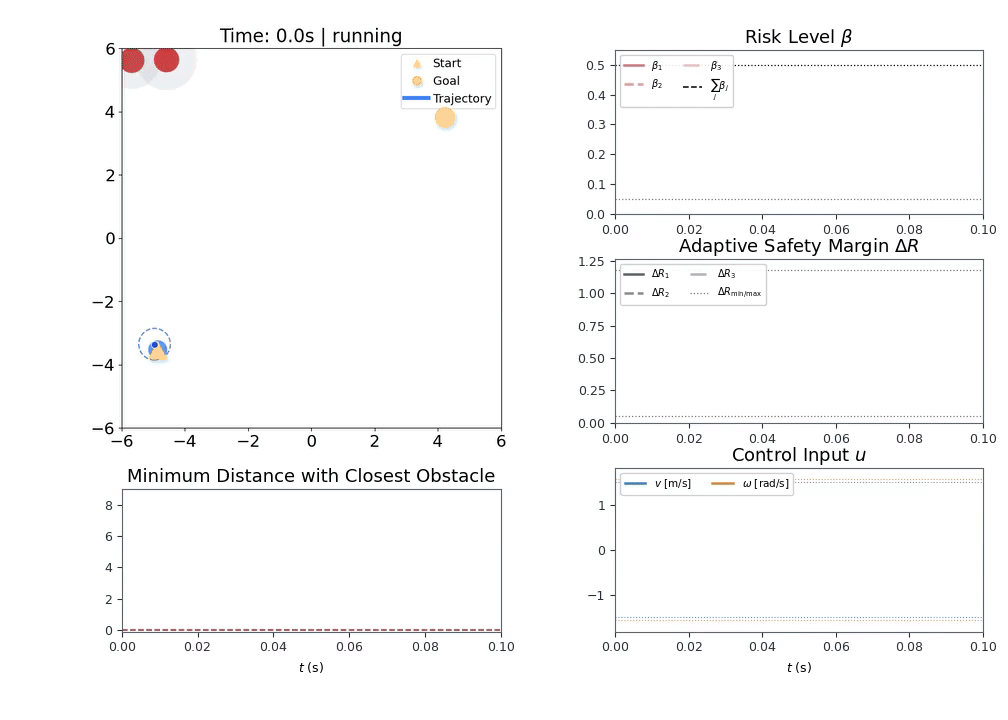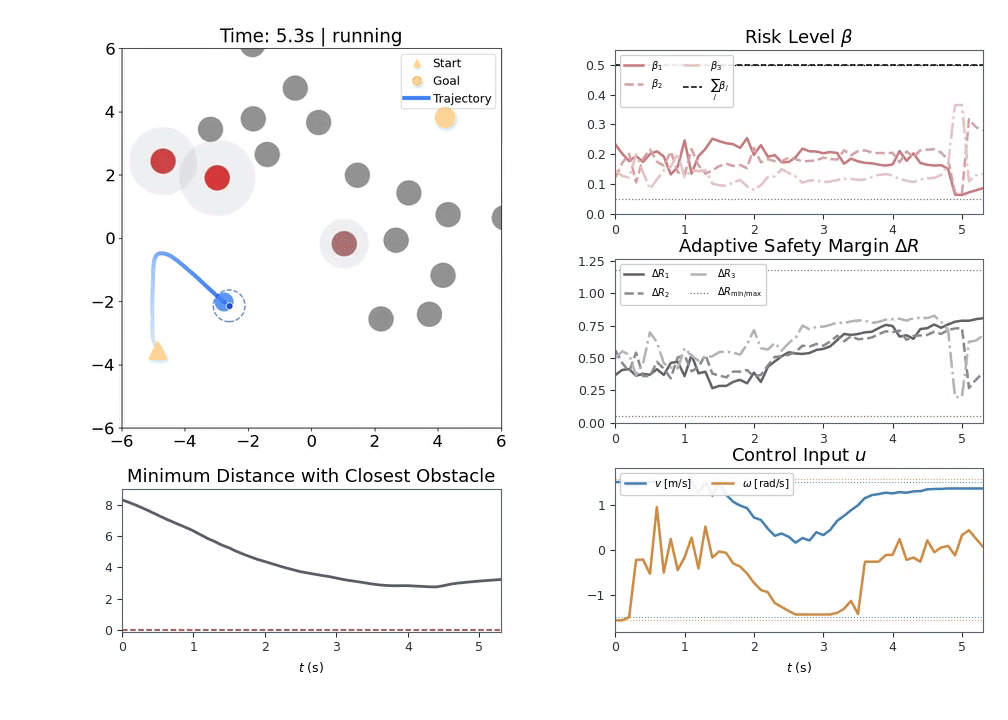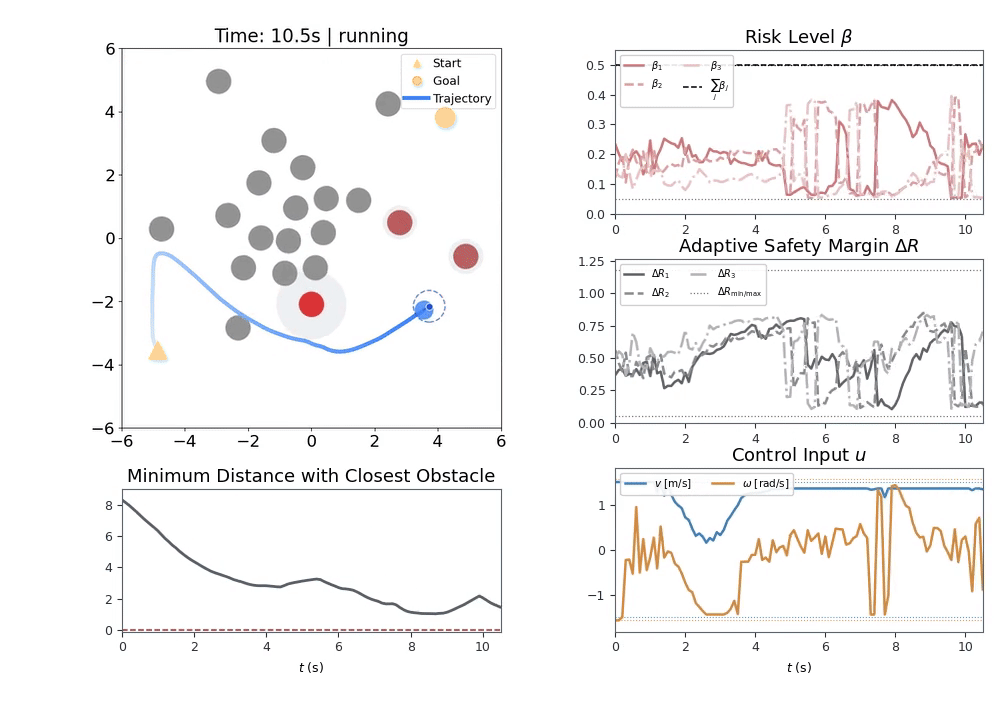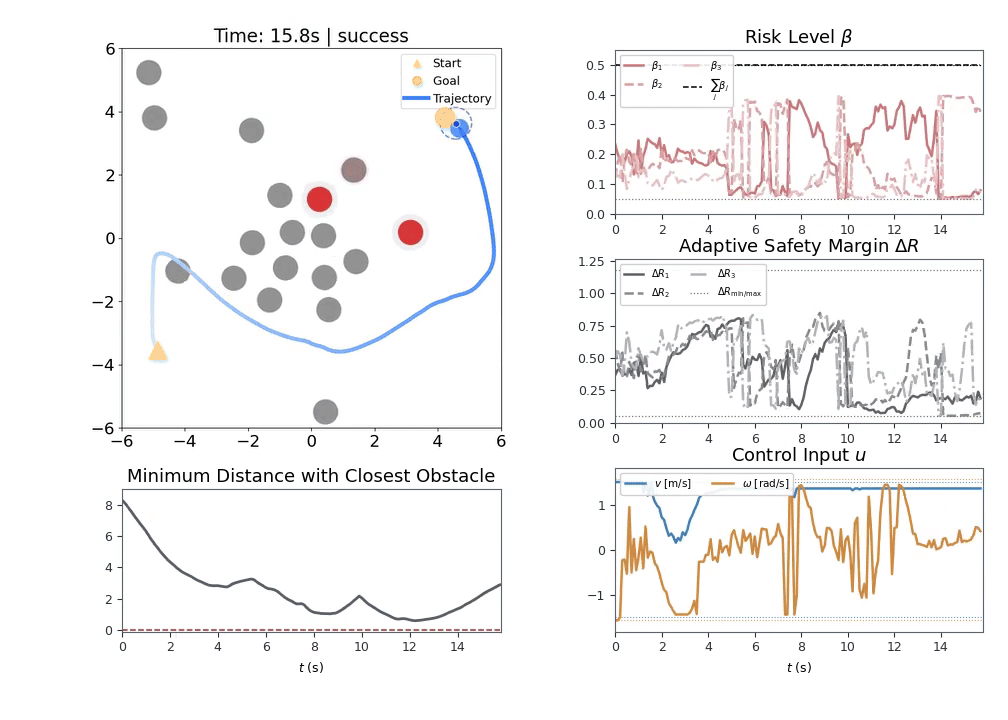
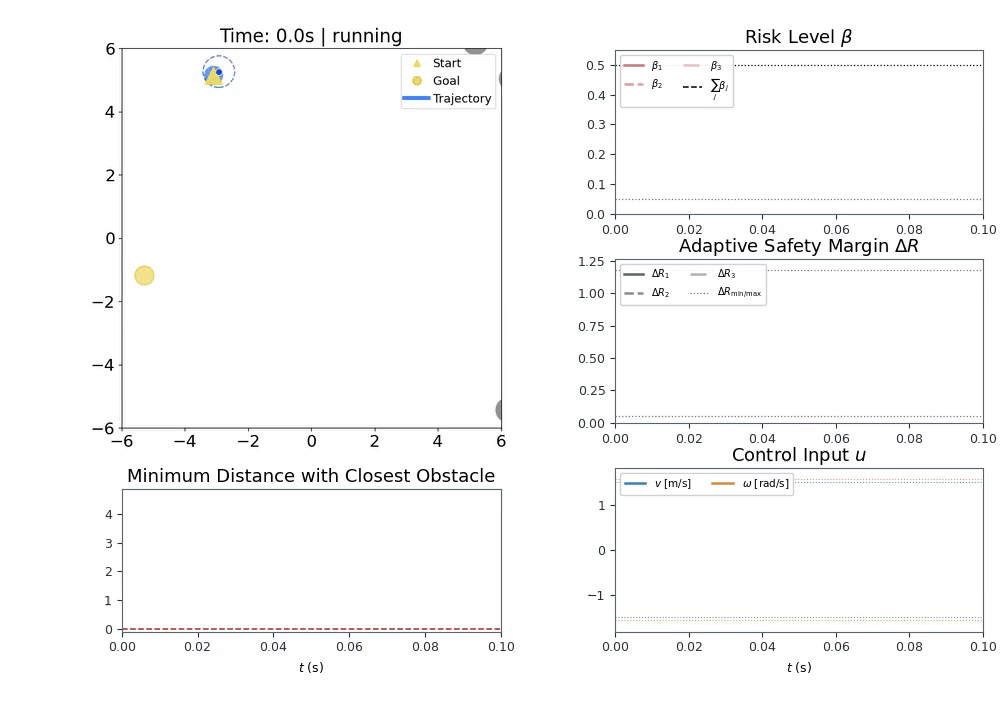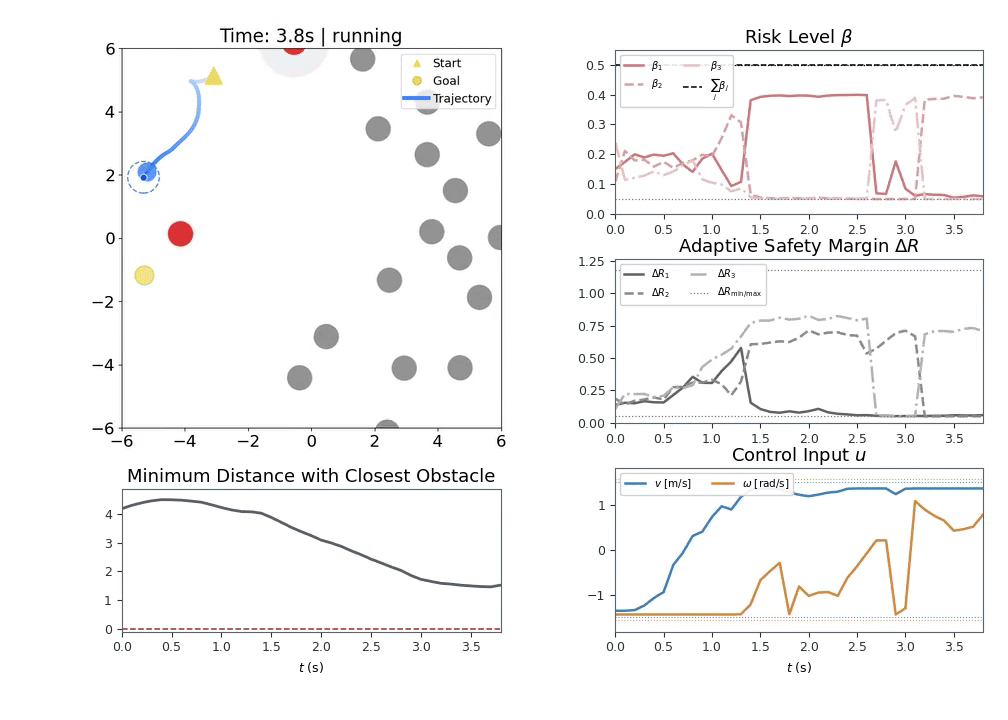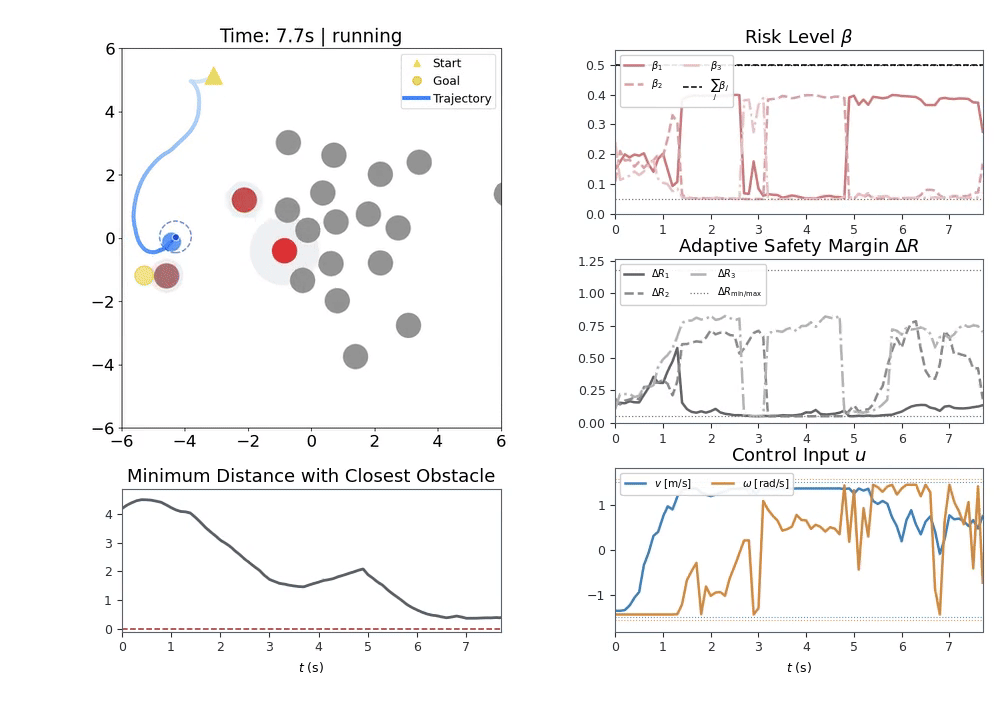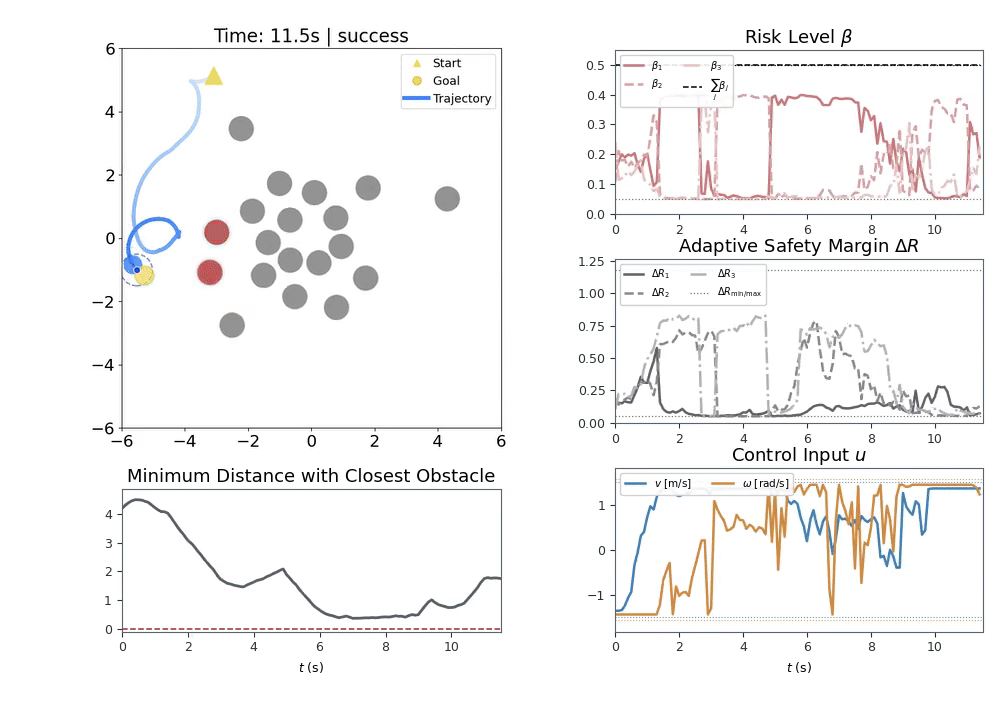
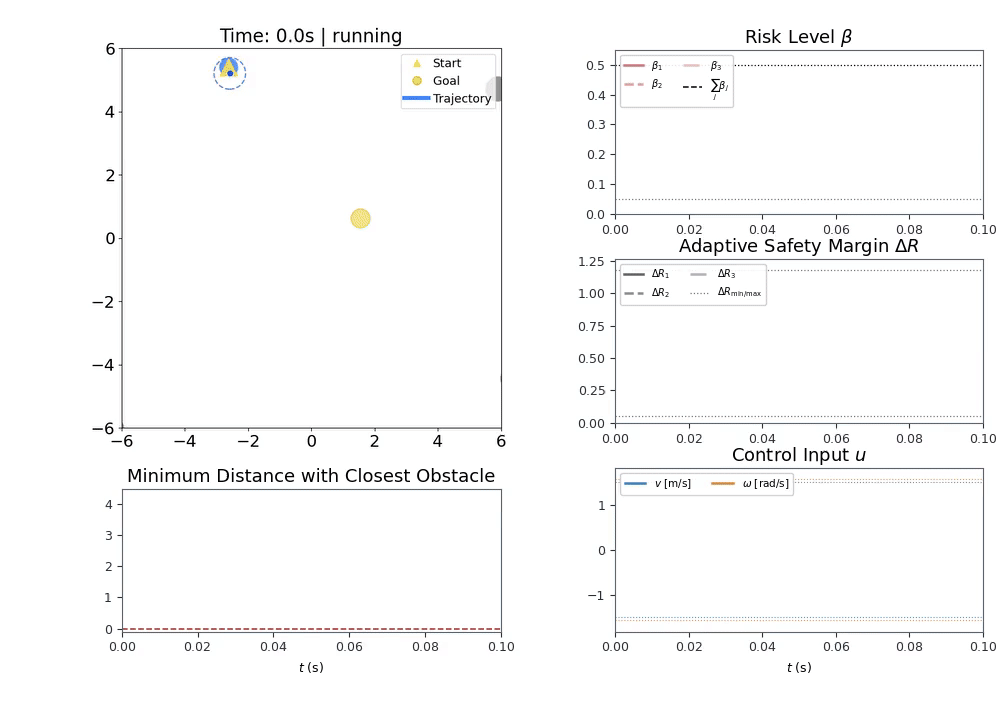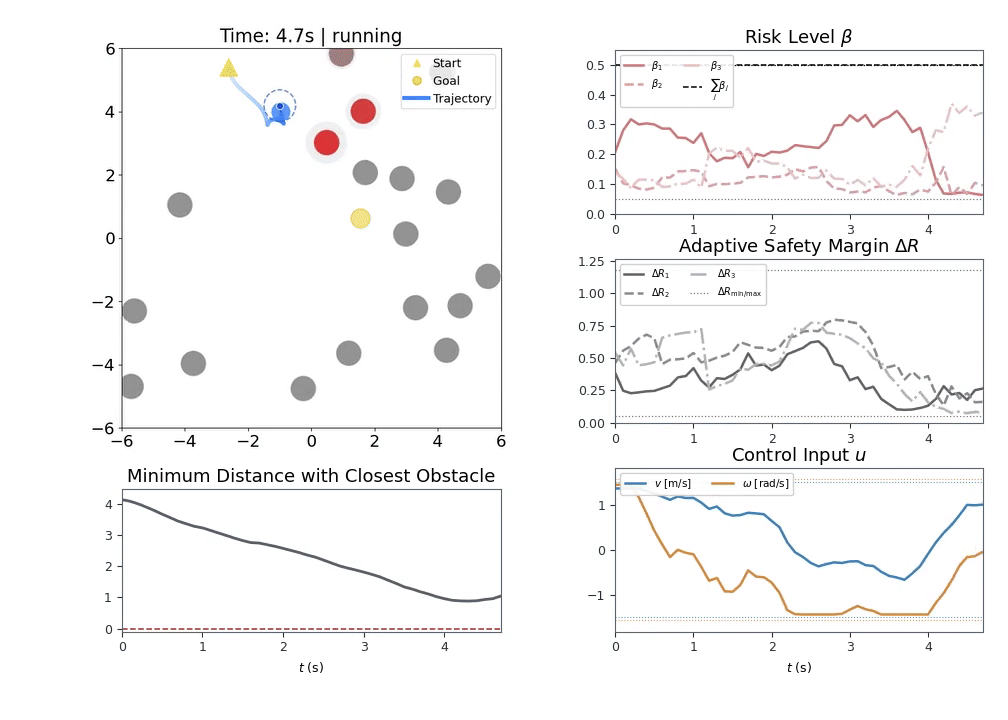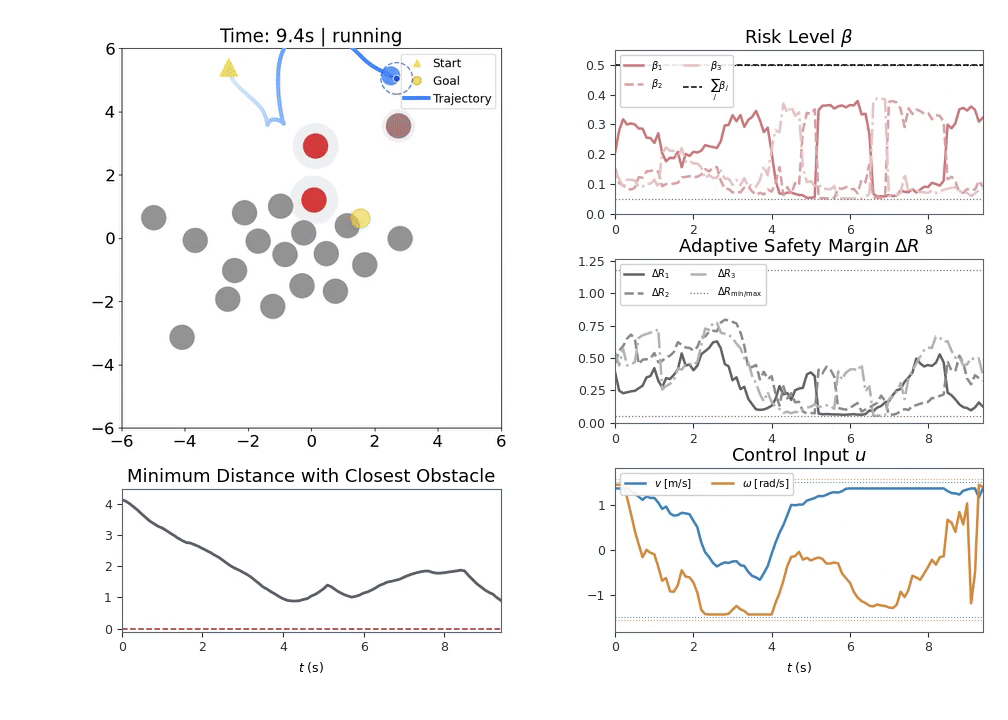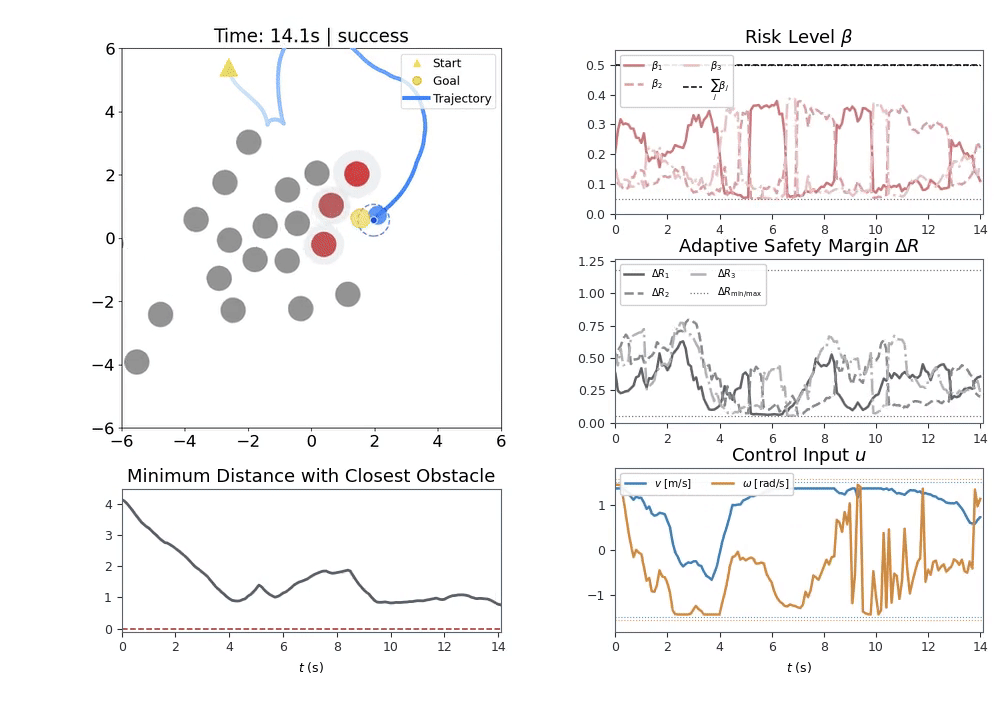
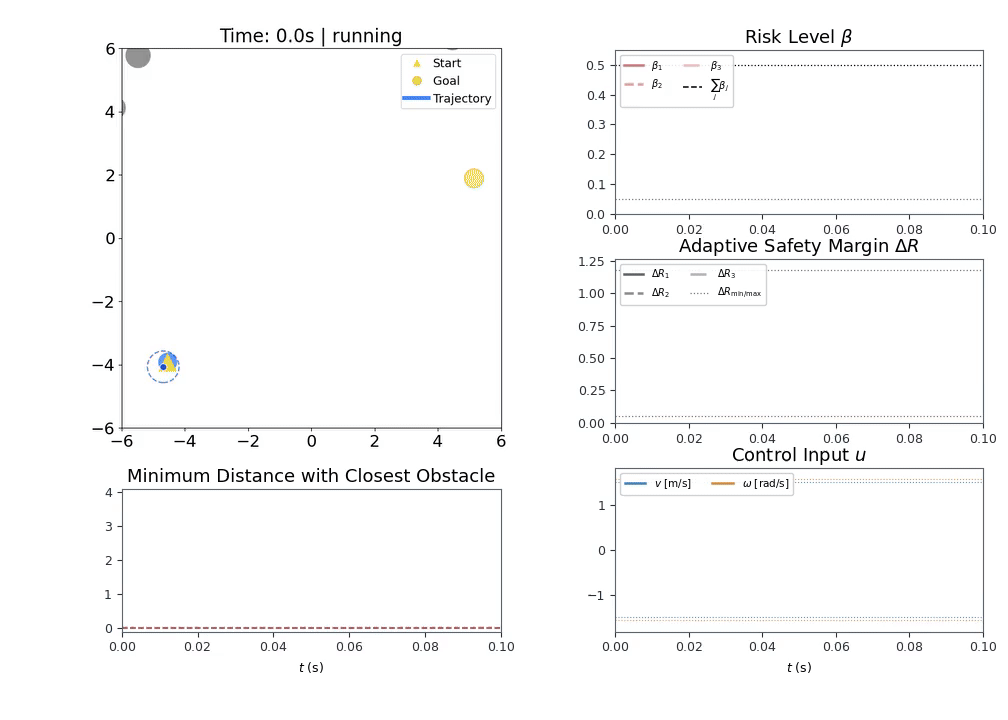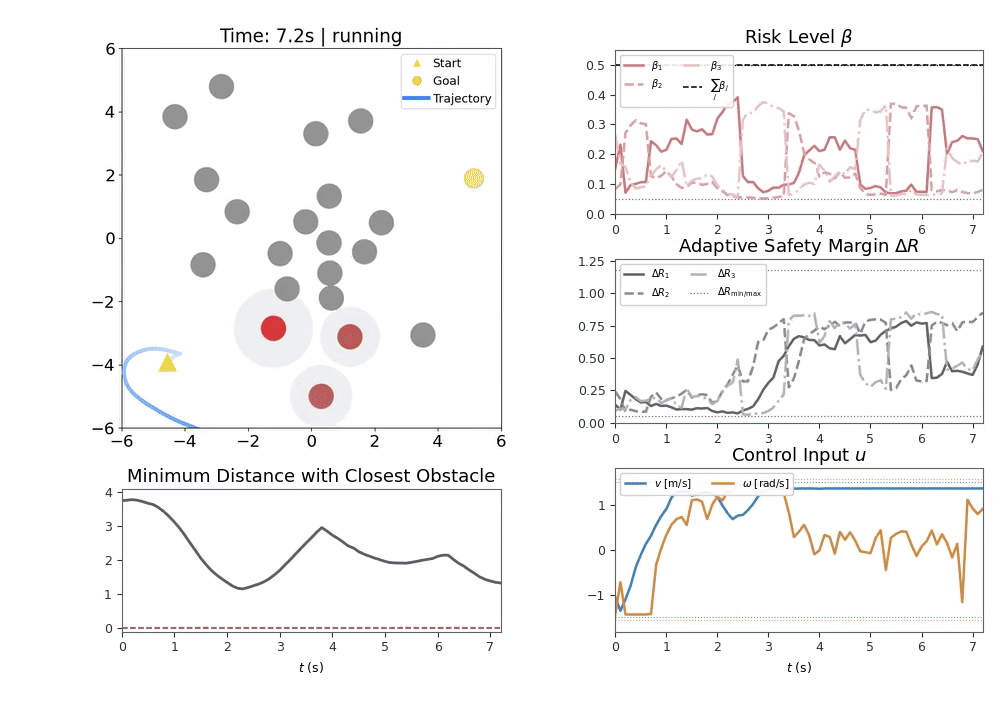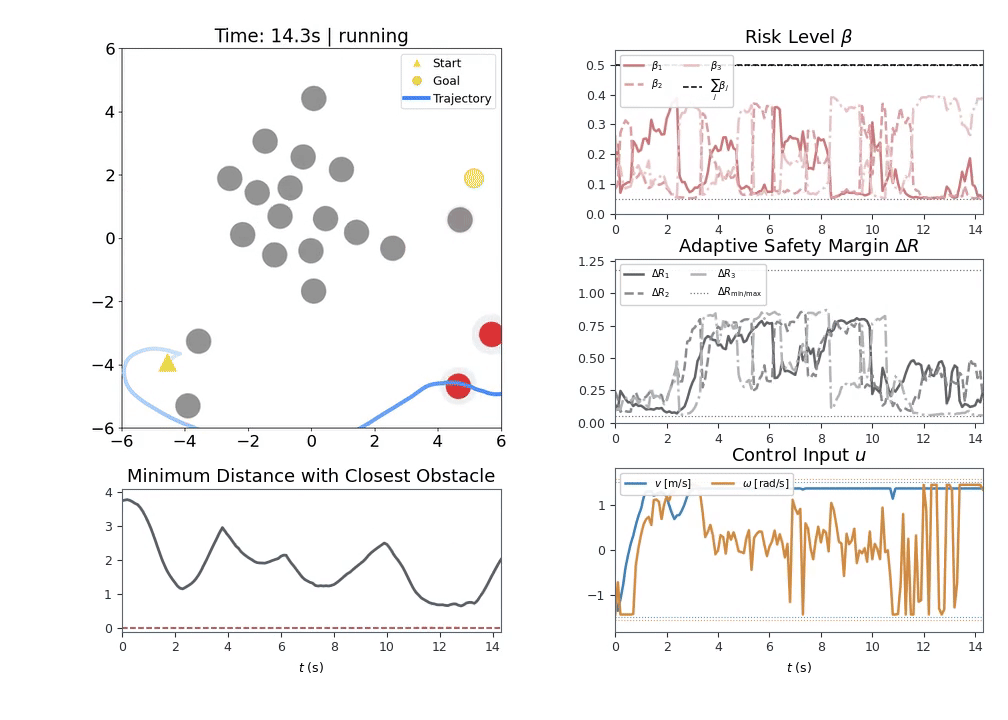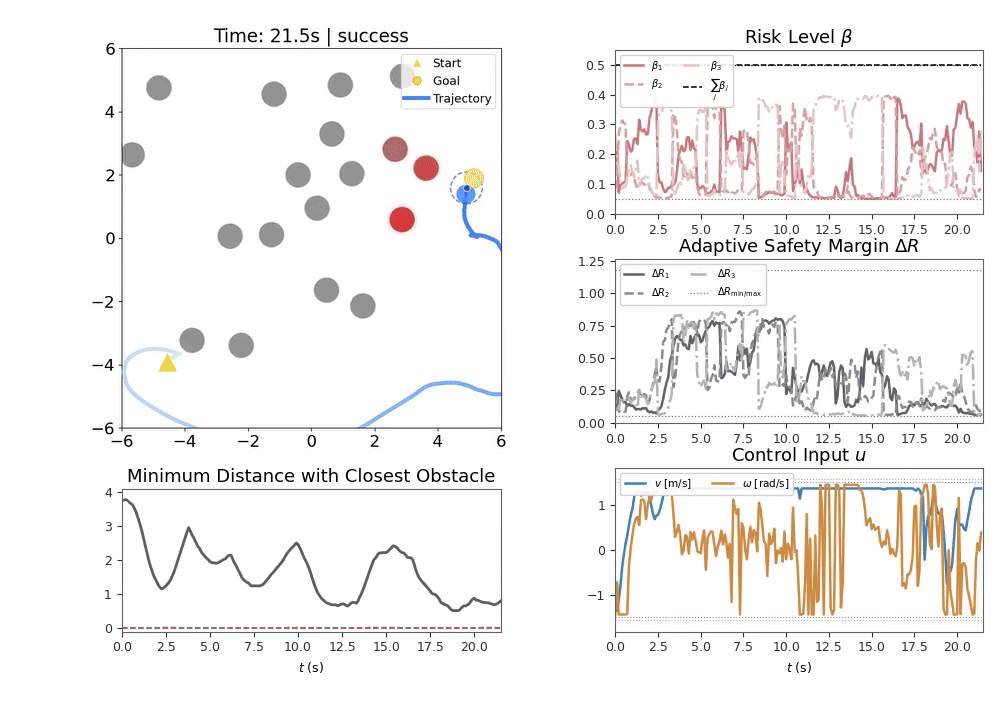
Environment & Uncertainty
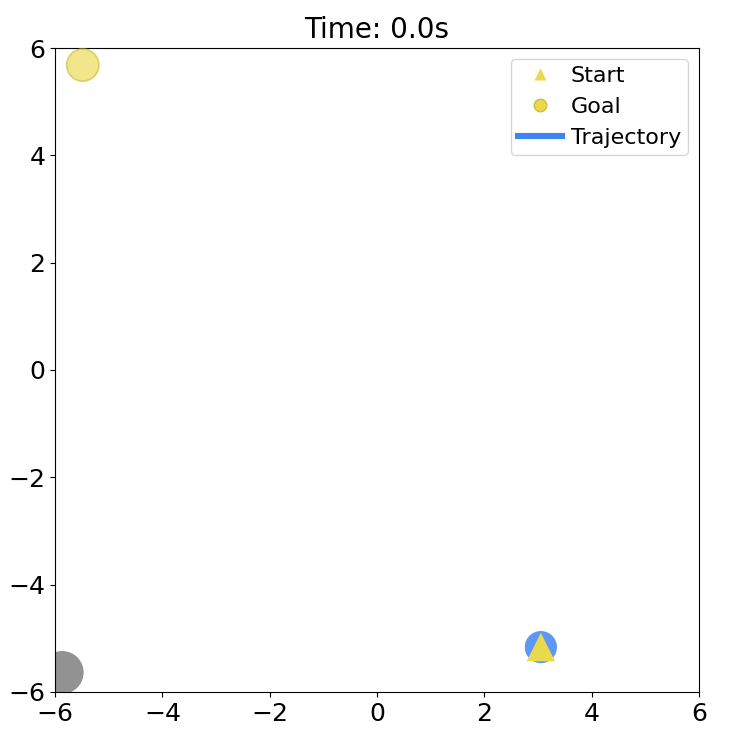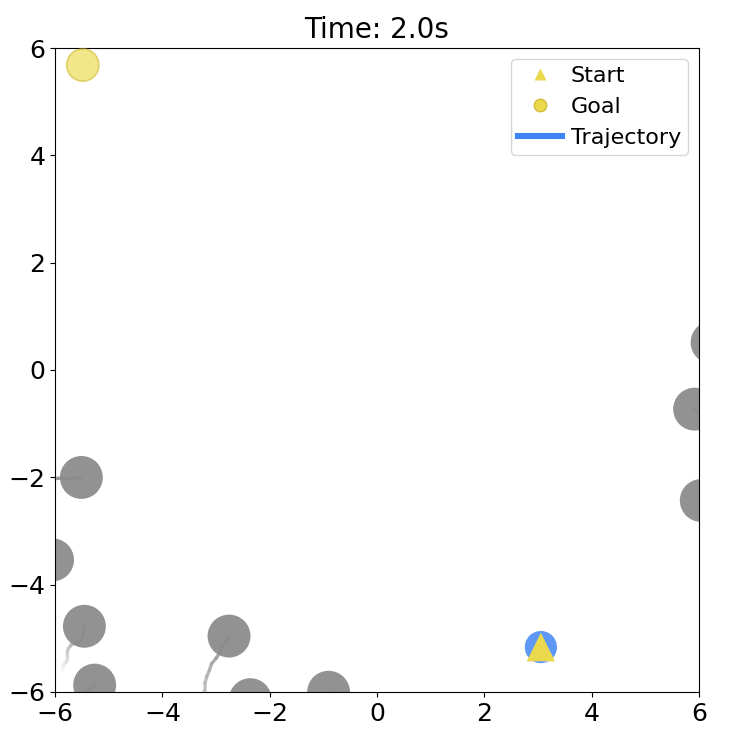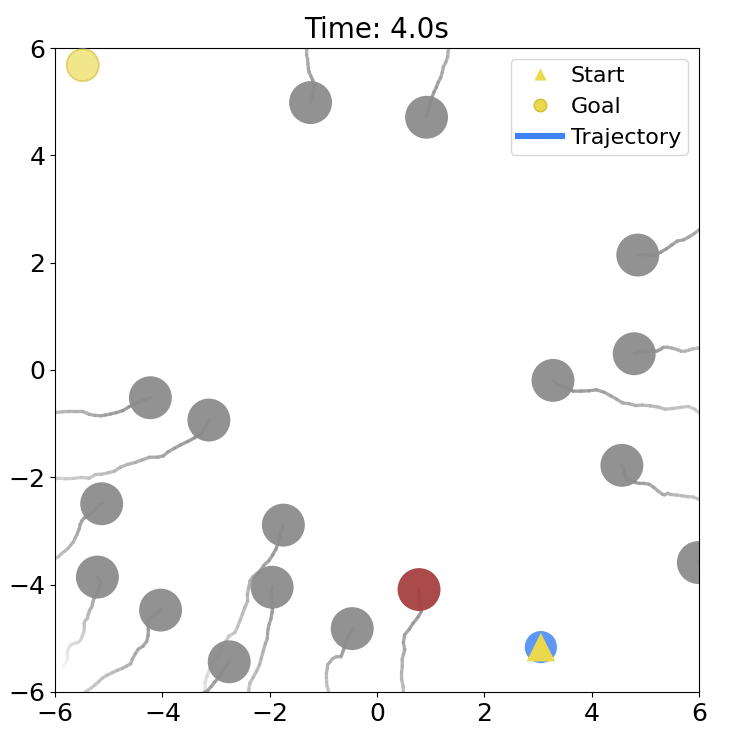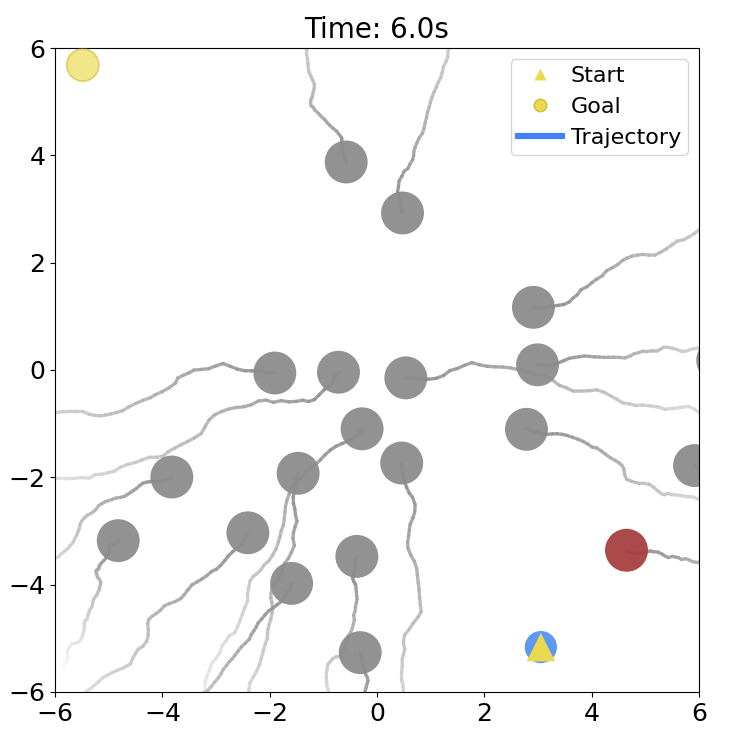
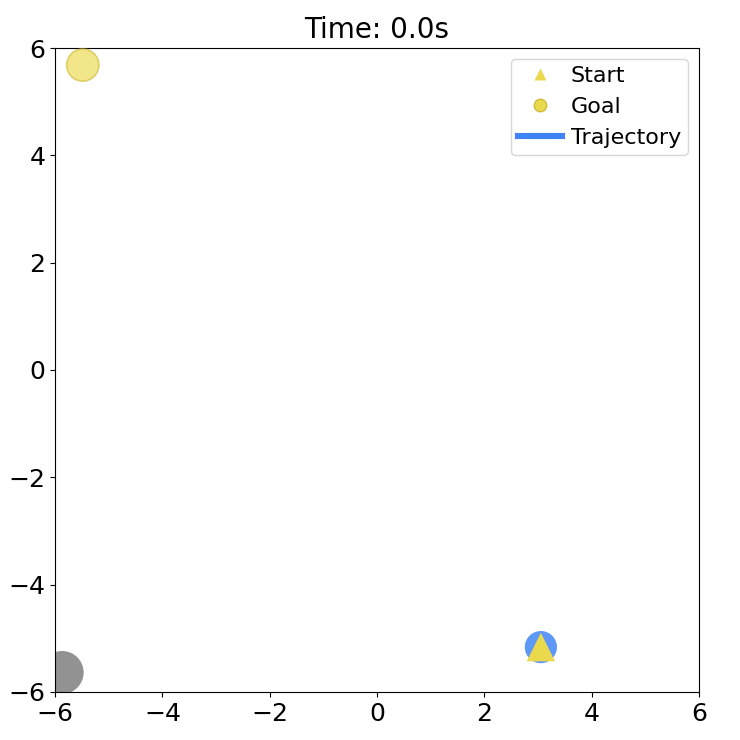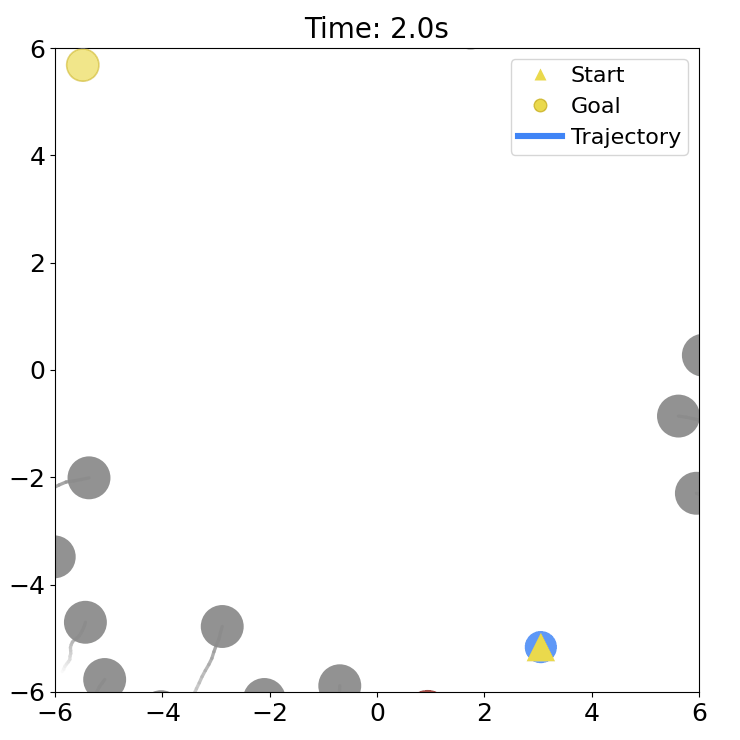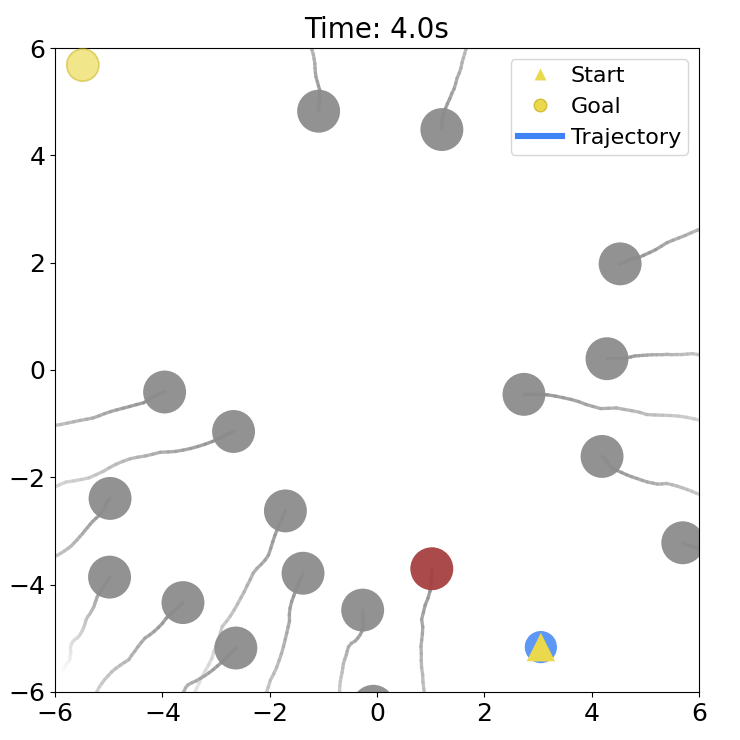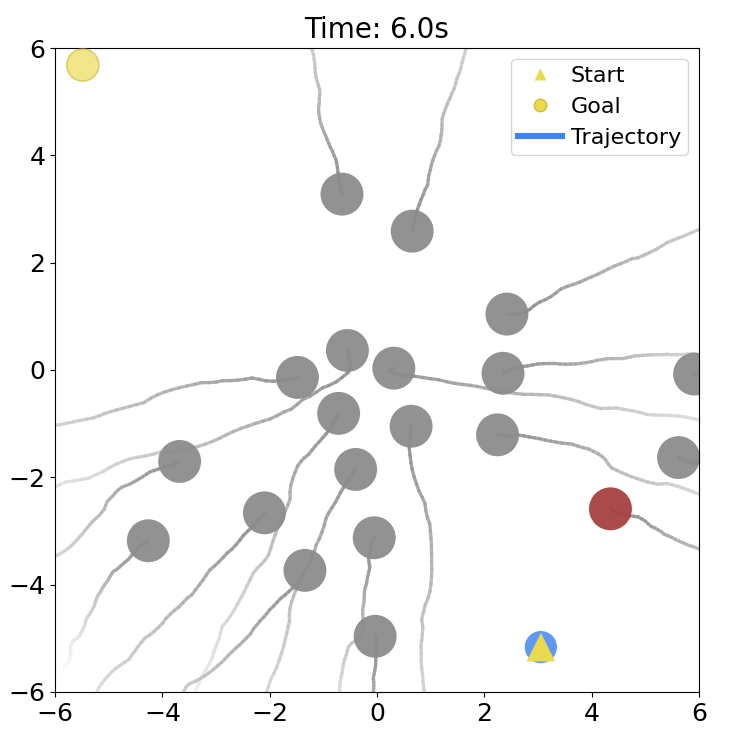
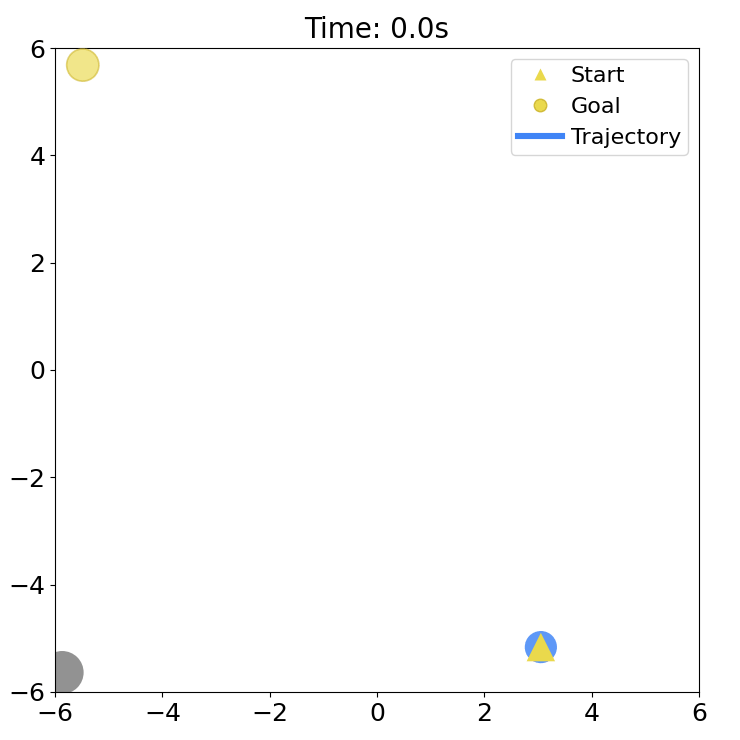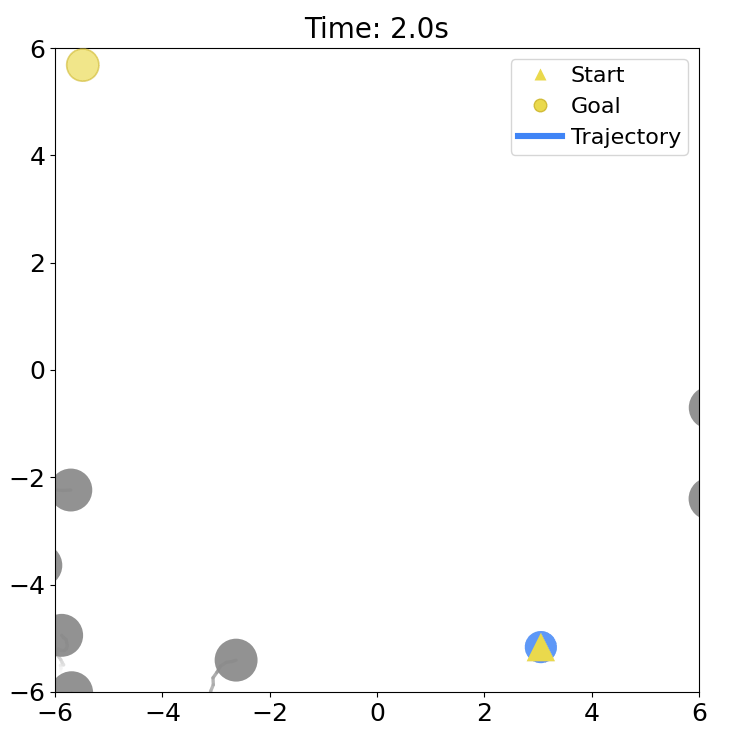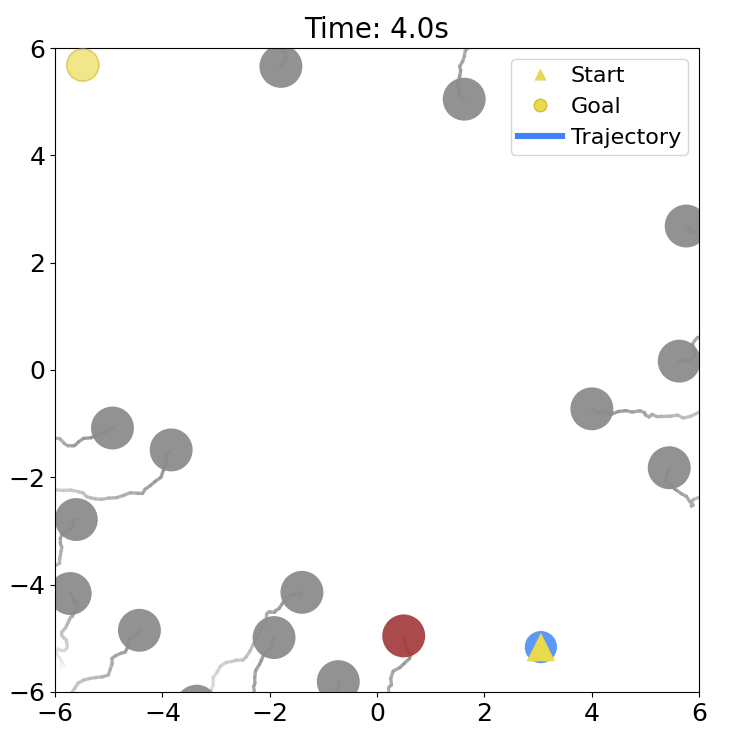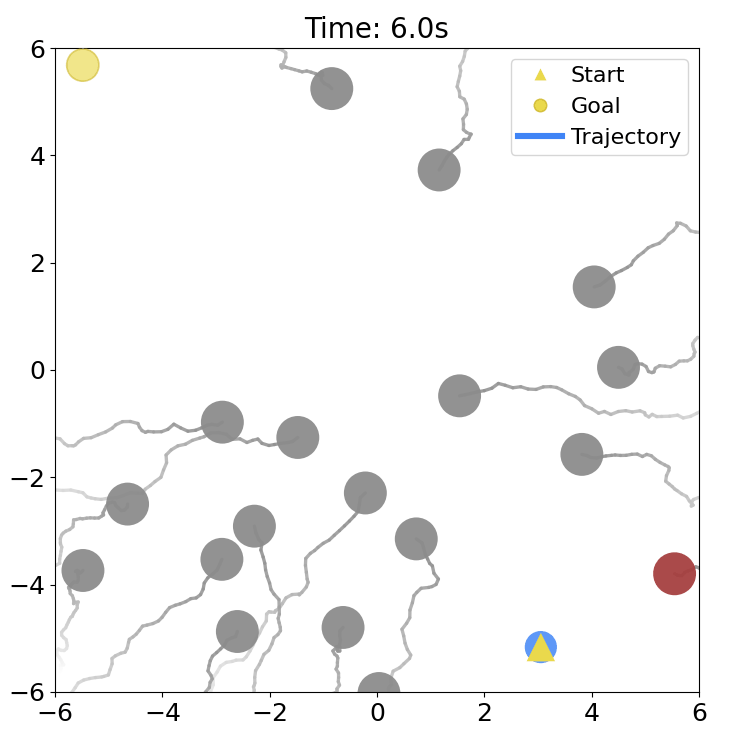
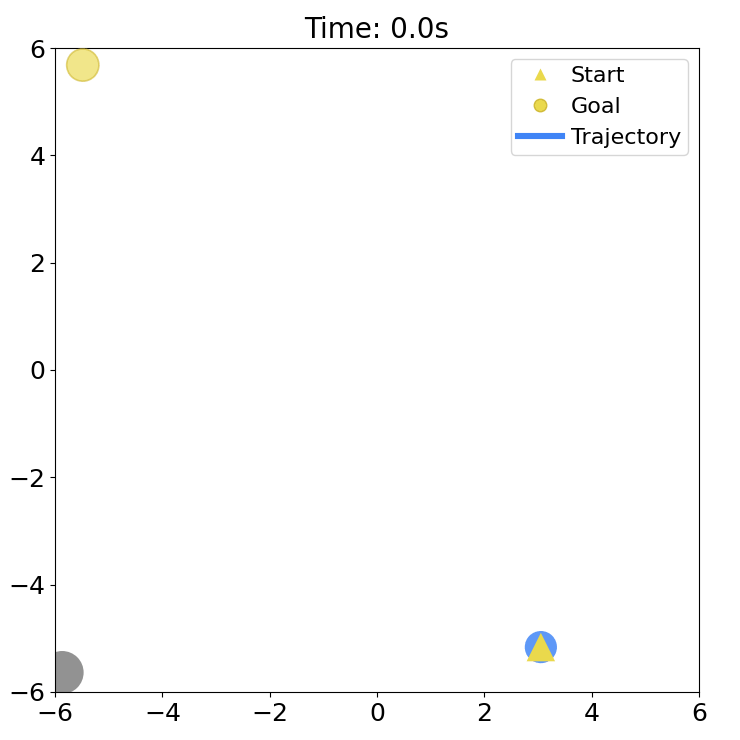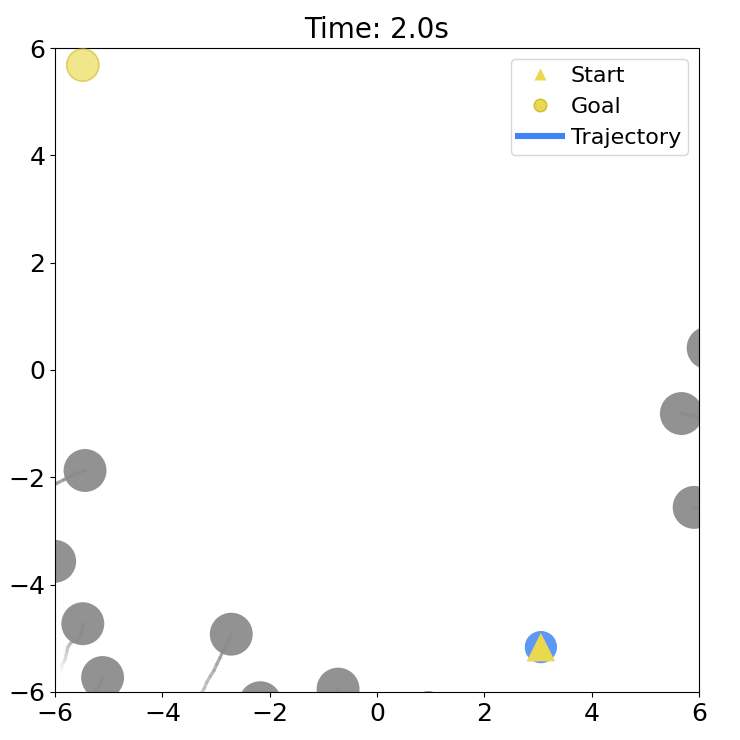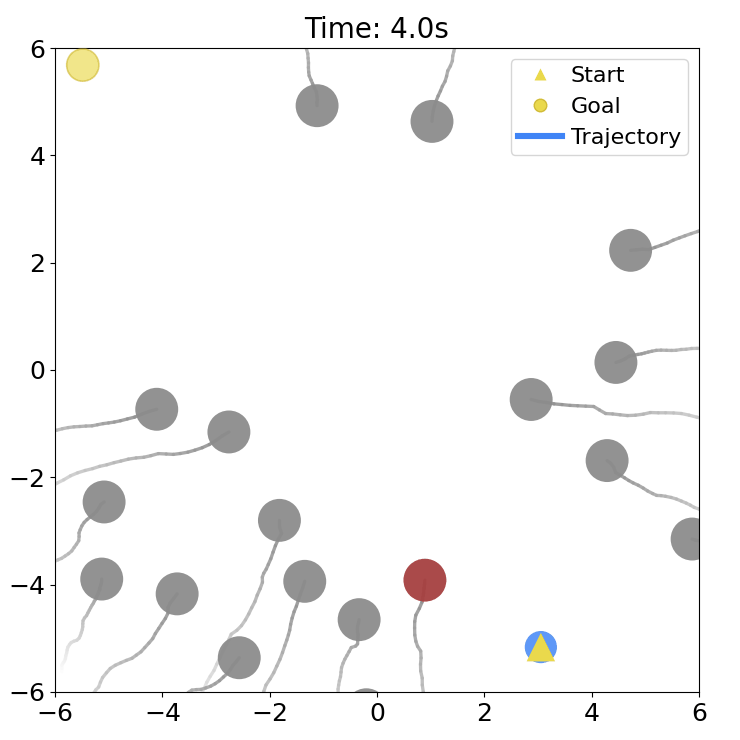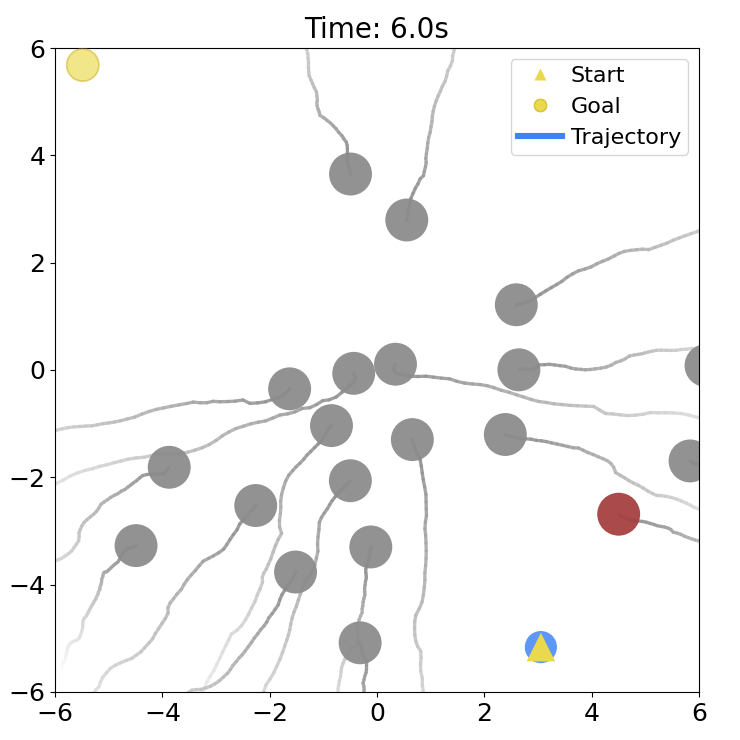
- Workspace
- [-6, 6] × [-6, 6] m
- Obstacles
- 20 dynamic circles; radius 0.4 m; speed in [0.5, 1.5] m/s
- Human motion
- Social-force policy with
avoid_robot = false - Uncertainty
- Three-mode GMM; weights [0.6, 0.2, 0.2], standard deviations [0.1, 0.2, 0.2], lateral ratio 0.3